MakarovSuites
English
EnglishDeutschРусскийУкраїнськаFrançaisEspañolItalianoPolski
Contact & licences

Math

Ant colony: trails and collective behaviour

Place food, interrupt a trail and watch a colony reorganise through local decisions.
Ant colony: trails and collective behaviour — Actual application image
Actual application image

Try this

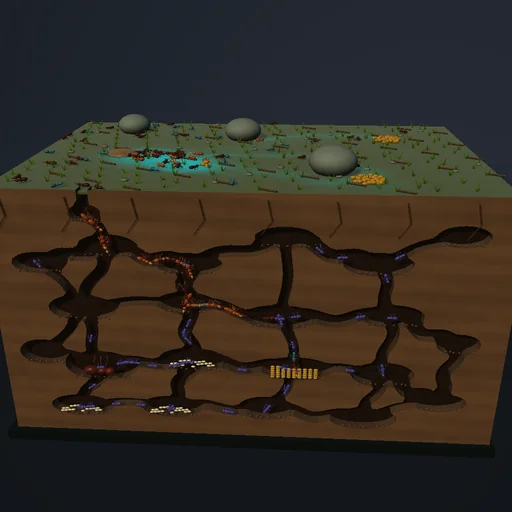
Left-click the ground to place food or a small obstacle. Right-drag rotates; the wheel zooms. Cyan marks food trails; gold ants carry food, blue ants scout and violet ants work inside. Close-up shows the nest section; the oblique view looks down on the trails.

The model and its limits

A local-agent teaching model with 22 connected chambers and 34 curved tunnels. Workers travel on the same passage graph shown in the cutaway, carrying food to stores and visiting brood and queen chambers. The fixed nest and population are prescribed; digging, births and species-specific biology are not simulated.

Equations used in the module
Equations
P(t + dt) = P(t) exp(-ln(2) dt / T)
food_added + food_initial = food_outside + food_carried + food_stored + food_consumed
Related experiments

Back to catalogue
Inversion: circles into lines — Actual application image

Math

Inversion: circles into lines

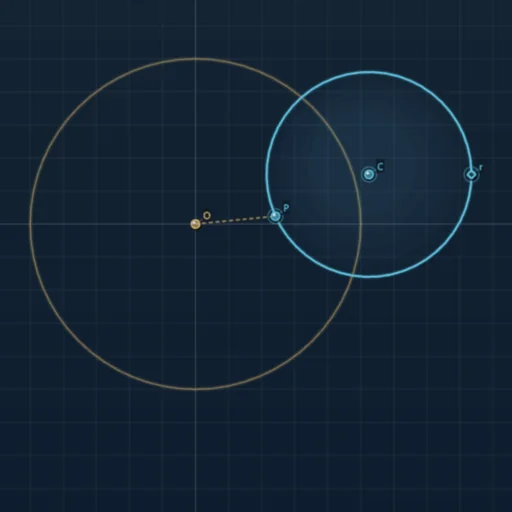
Drag C to move the circle, the diamond r to resize it, or P along its rim. Take the circle through O and compare its image. The brass ring has R = 1; points on it stay fixed. Adjust ρ until the last circle touches the first after one turn. The same numbered circles correspond across the two views. Start lets the chain slide; a closed chain stays closed.

The inscribed angle and its half — Actual application image

Math

The inscribed angle and its half

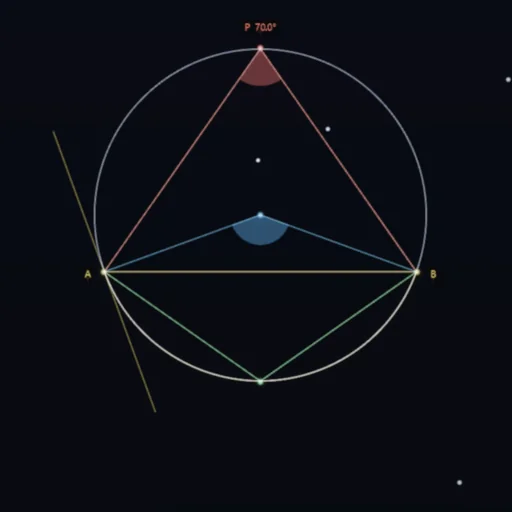
Keep AB fixed. Predict whether the angle will change, then move P and check. The highlighted arc never contains P. Reveal four steps using diameter PD and equal radii. The same construction works by adding or subtracting the small angles; try both cases.