Engineering
Walking linkage: the geometry of a step
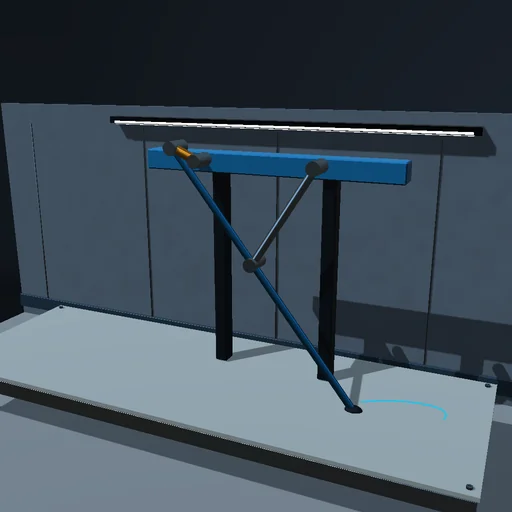
A closed four-bar leg turns rotation into a curved foot path. Compare the linkage with its measured trajectory.
Try this
Change the crank radius and leg extension. Follow the joints and the returning foot.
The model and its limits
Rigid four-bar geometry with a prescribed crank. The cyan curve is one full foot cycle. Contact, balance and forward locomotion are not simulated.
Equations used in the module
Equations
|B - A| = L
|B - O| = R