MakarovSuites
English
EnglishDeutschРусскийУкраїнськаFrançaisEspañolItalianoPolski
Contact & licences

Engineering

Ackermann steering: four wheels, one turning centre

Turn the front wheels and compare the inner and outer angles required for rolling around a shared centre.
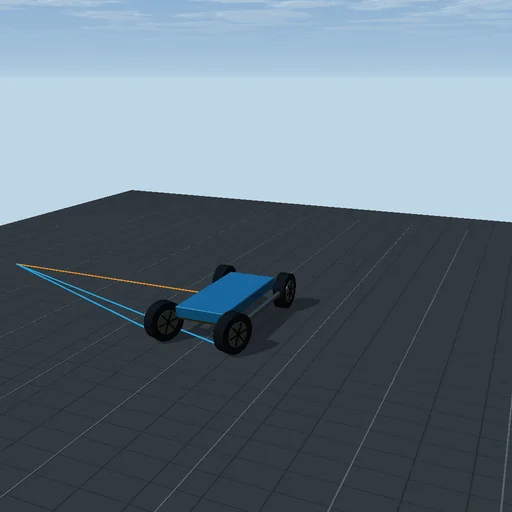
Ackermann steering: four wheels, one turning centre — Actual application image
Actual application image

Try this

Increase steering and compare the inner and outer wheel angles. The lines meet at the turning centre.

The model and its limits

Pure rolling kinematics. No tyre slip, suspension compliance or steering-force calculation. The chassis stays fixed for inspection.

Equations used in the module
Equations
cot(delta_outer) - cot(delta_inner) = track / wheelbase
R = wheelbase / tan(delta)


Related experiments

Back to catalogue
Quadruped terrain lab — Actual application image

Physics / Engineering

Quadruped terrain lab

Explore four-legged locomotion, terrain, grip and balance with an articulated 3D robot.

Forklift warehouse — Actual application image

Physics / Engineering

Forklift warehouse

Drive a forklift and transport pallets with loose crates that interact through contact and friction.