Math
Eigenvectors
Explore power iteration: repeated multiplication can align vectors with a dominant eigenvector. Compare the measured angular error with the asymptotic spectral ratio, and inspect the Rayleigh quotient for symmetric matrices.
What happens
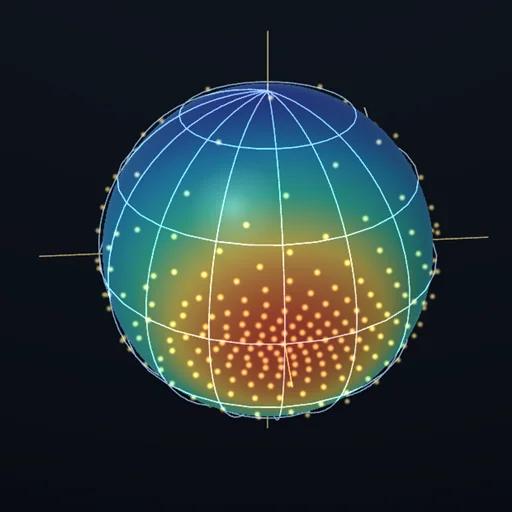
Each step multiplies the unit vectors by the matrix and normalises them again. For a diagonalizable matrix with one eigenvalue strictly largest in modulus, an initial vector with a nonzero component along its dominant eigendirection approaches that line. A specially chosen initial vector can miss the dominant direction.
The ratio |λ₂/λ₁| describes the generic asymptotic geometric rate; it is not an exact ratio of successive angles at every step. Missing a subdominant component can make convergence faster, while numerical roundoff eventually limits the measured angle. The nearly degenerate preset converges slowly. The defective shear has algebraic rather than geometric convergence. A rotation or dominant complex pair generally keeps directions turning; a negative dominant eigenvalue flips the vector sign while its line settles.
For a symmetric matrix, the Rayleigh quotient on the unit sphere has extrema at eigenvectors of the smallest and largest algebraic eigenvalues. Click the sphere to choose a different initial vector and compare the measured path with the spectral prediction.
Equations used in the module
Equations
A·v = λ·v
v_(k+1) = A·v_k / ||A·v_k||
|λ₁| > |λ₂|, c₁ ≠ 0
ε_k = O(|λ₂/λ₁|^k)
R(v) = (v·A·v)/(v·v)
A = Aᵀ ⇒ λ_min ≤ R(v) ≤ λ_max
tr A = Σλ, det A = Πλ