Physics
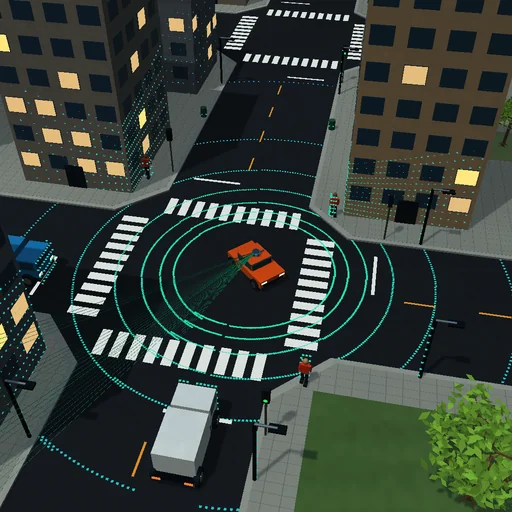
Lidar car: scanning the world
A moving laser scanner measures a three-dimensional point cloud.
Try this
Watch the orange car follow its lane, brake for measured lidar obstacles and yield at signals. Cars and pedestrians choose different routes and enter or leave the map. Camera tracking remains active when you zoom in or out. The plot shows measured range by azimuth.
The model and its limits
Ideal ray intersections provide the point cloud and obstacle braking. A lane graph, traffic signals, reserved crossings and geometric safety guards coordinate individual actors. Vehicles follow smooth kinematic paths. This is an illustrative traffic controller, not SLAM, image recognition or validated autonomous driving.
Equations used in the module
Equations
r = c Δt / 2
v² ≤ 2 a d