MakarovSuites
English
EnglishDeutschРусскийУкраїнськаFrançaisEspañolItalianoPolski
Contact & licences

Physics

Magnetic levitation under control

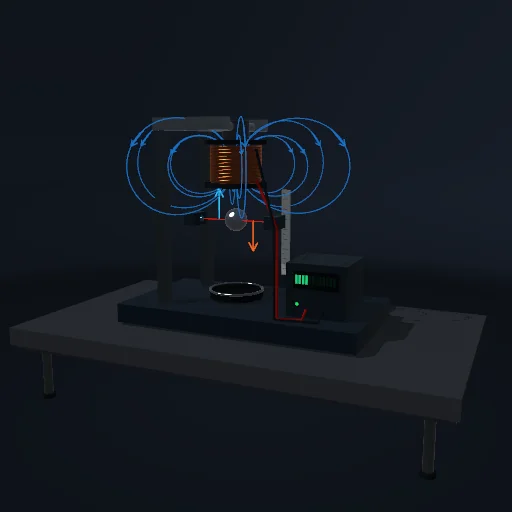
A feedback controller holds a steel ball below an electromagnet. A nonlinear force law, coil lag, current saturation and contact stops make disturbances and loss of control visible.
Magnetic levitation under control — Actual application image
Actual application image

Try this

The controller regulates coil current to hold the steel sphere. The red optical line marks the target height. Disturb the ball or disable feedback. Blue curves illustrate the field; their brightness follows current.

Equations used in the module
Equations
m x″ = m g − c i²/x² − b x′
i* = x √[m(g + Kp(x − x*) + Kd x′)/c]
τ i′ = i* − i; 0 ≤ i ≤ 5 A
Related experiments

Back to catalogue
Cubli: a cube balancing on its edge — Actual application image

Physics

Cubli: a cube balancing on its edge

A planar cube balances on an edge using a reaction wheel. Disturb the controller or launch it with a momentum-conserving wheel-brake impulse.

Why a bicycle stays up — Actual application image

Physics

Why a bicycle stays up

Explore self-stability in the linear Whipple bicycle benchmark. Speed, trail, steering-axis tilt and wheel gyroscopic terms change the freely evolving lean and steer response.

Forklift warehouse — Actual application image

Physics / Engineering

Forklift warehouse

Drive a forklift and transport pallets with loose crates that interact through contact and friction.