Engineering
Cable camera robot
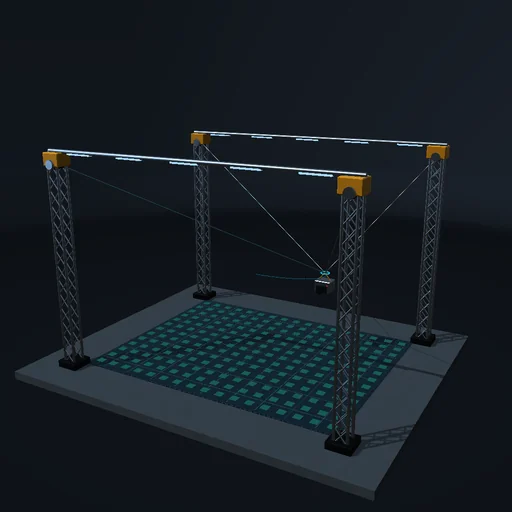
Four finite-power winches carry a camera through an arena. Explore tension, passive sway, slack cables and the limits of the reachable workspace.
Try this
Start with a slow route. Watch each cable tension, then add wind or shift the load. A target outside the static feasible region is rejected. With a held target, try paying out the first cable.
The model and its limits
Four cables share one swivel above the payload. Attitude is passive, not independently controlled. The coloured floor shows static feasibility at the manual target height; moving loads can still saturate a winch. Cable sag is illustrative.
Equations used in the module
Equations
Σ T_i n_i + m g = 0
0 ≤ T_i ≤ T_max
P_i = -T_i dl_i/dt
m dv/dt = Σ F