Astronomy / Engineering
Lunar rover expedition
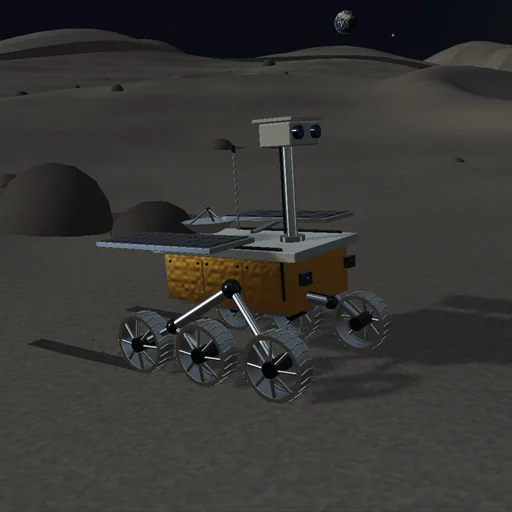
Drive a six-wheel rover across a cratered lunar test field. Compare grip, suspension loads and the automatic survey route.
The model and its limits
Six bounded spring contacts, friction-limited traction and fixed ellipsoidal rocks. Small stones support the wheels; large rocks collide with the rover footprint. The chassis follows a damped support plane. No soil deformation, movable boulders or full rocker-bogie dynamics. Earth has an approximately 1.9° apparent diameter; stars are exposure-enhanced. Terrain is synthetic, not a surveyed lunar location.
Equations used in the module
Equations
N_i = max(0, k (l0 - l_i) - c v_y); |F_t| <= mu sum(N_i); m dv/dt = F_t + F_side + F_g