Engineering
Pipe inspection robot
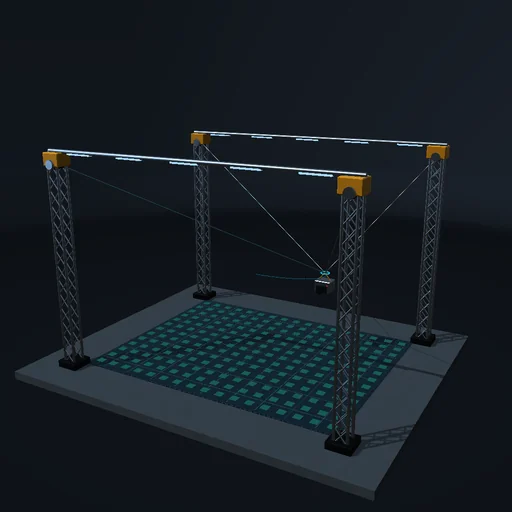
Drive an inspection robot into a dark, rusted pipeline by the light of its own headlamp: three wheel pairs pressed against the wall give it traction mu N, the tether it drags behind grows heavier with every metre along the floor and every metre of the climb, and each bend multiplies its tension by the capstan factor e^(mu theta). Watch it run up the riser, through the bends and on until the tether wins and the wheels spin - a few decimetres short of the closed-form stall point. Ease the preload until it cannot climb its own weight, or give it a slicker tether and it reaches the end; the motor’s work is followed into height, tether, rolling, scrubbing and slip.
What happens
A 12 kg robot in a 0.5 m pipeline: three wheel pairs pressed against the wall with 260 N give it a traction of mu_w N = 156 N; a speed controller drives the wheels up to the motor’s 160 N. The route runs 25 m level, climbs 8 m, runs 40 m, turns twice and runs 100 m more. Behind the robot the tether’s tension grows by mu_t w per metre along the floor, by w per metre up the climb and by the capstan factor e^(mu_t pi/2) in every bend. Gravity on the climb, rolling resistance and the tyres’ scrubbing join the tether against the wheels; where they exceed the traction the wheels slip. Semi-implicit steps of 10 ms; the motor’s work is followed into height, tether, rolling, scrubbing and slip heat.
Try this
Drive the robot in and watch the tether tension grow through the bends; read where it stalls against the closed-form stall point; ease the preload until it cannot climb; give it a slicker tether.
The model and its limits
A rigid robot on a fixed route, Coulomb friction for wheels and tether, a capstan law in the bends, no tether stretch or snagging. Reach is that of this idealized robot.
Equations used in the module
Equations
F_traction = μ_w·N,  dT/ds = μ_t·w (level),  dT/ds = w (climb)
T_out = T_in·e^(μ_t·θ) in every bend
m·a = min(F_drive, μ_w·N) − T − m·g·sin α − c_r·N − c_s·v
W_motor = ΔE_p + ∫T ds + W_roll + W_slip + E_k