Physics / Engineering
Robot arm workshop
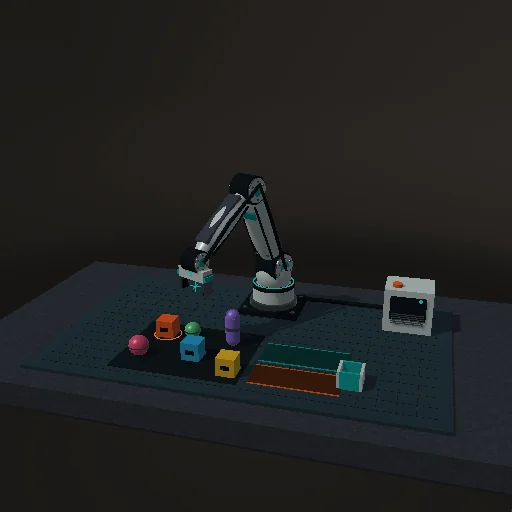
Control a six-axis robot arm, grasp physical objects, sort a mixed batch or build a tower. Explore inverse kinematics, joint limits and payload with the suite’s 3D contact solver.
What happens
Control a six-axis robot arm, grasp physical objects, sort a mixed batch or build a tower. Explore inverse kinematics, joint limits and payload with the suite’s 3D contact solver.
The arm uses prescribed servo motion with speed, acceleration and table-clearance limits. Its two main links collide with objects. Loose bodies use the shared 3D sandbox solver at 120 Hz. A nearby grasp engages three ideal no-slip constraints; opening preserves momentum. This is assisted grasping, not a simulation of finger friction or motor torque. The automatic planner lifts before transfer; it is not a general obstacle-avoidance planner. Move selected, sort six objects or stack the three cubes. Held-load travel is limited to 0.65 m/s.
Try this
Click an object to approach it. Arrows: X/Z; Q/E: height; G: grip; H: home. Right drag: orbit. Wheel: zoom. Lower the tool to the object’s center before closing.
Equations used in the module
Equations
r² = dx² + dz²
cos θ₃ = (r² + dy² − L₁² − L₂²) / (2 L₁ L₂)
θ₂ = atan2(dy, r) − atan2(L₂ sin θ₃, L₁ + L₂ cos θ₃)
θ₄ = −π/2 − θ₂ − θ₃
F = m g;  Δv = J / m