Physics / Engineering
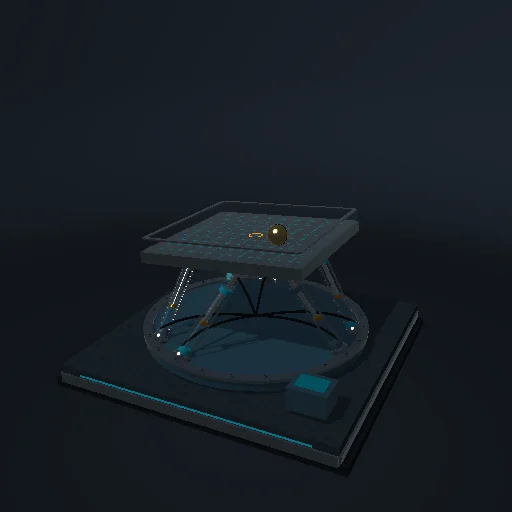
Stewart balancing platform
Control a six-actuator parallel robot and balance a freely rolling ball on its moving platform.
What happens
Click the platform to move the target or nudge the ball. Manual pitch/roll act in Manual mode. Six lengths come from inverse kinematics; the ball rolls with gravity, friction and collisions. Actuators prescribe a rate-limited pose; motor forces and flexibility are not simulated.
Equations used in the module
Equations
Li = |p + R ai − bi|
Ball target acceleration: ac = kp (target − x) − kd v