Astronomy / Engineering
A station arm moves its cargo
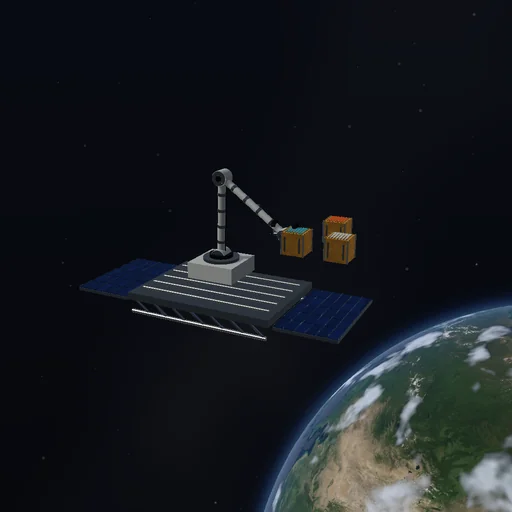
Use a station-mounted arm to capture floating cargo and move it into the service area. Compare automatic transfer with manual tool positioning.
The model and its limits
Sandbox rigid-body contacts and three capture constraints. The station is externally held; the two-link servo arm has massless links and limited reach. Links do not collide with cargo; payloads and the base do.
Equations used in the module
Equations
P = sum(m_i v_i); J_A = -J_B; F_support != 0; |r_tool| <= 2.65 m