Astronomy / Engineering
A robot without a fixed base
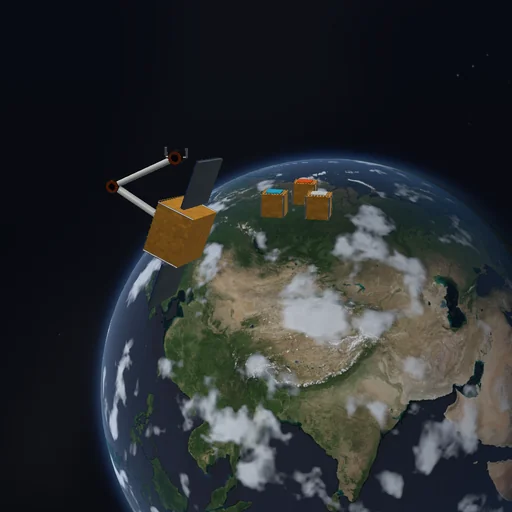
Catch a drifting payload with a robot that has no fixed support. Moving the captured load pushes and turns the floating base through the same contact solver.
The model and its limits
Zero-gravity sandbox with floor, damping and sleeping disabled. Capture impulses act on payload and base. The two links carry mass: moving the arm shifts and turns the free base so the system’s centre of mass and angular momentum stay put; arrow-key attitude jets apply external torque. No orbit-gradient forces in this local work volume.
Equations used in the module
Equations
P = sum(m_i v_i); dP/dt = 0; J_A = -J_B; |r_tool| <= 2.65 m