Physics / Engineering
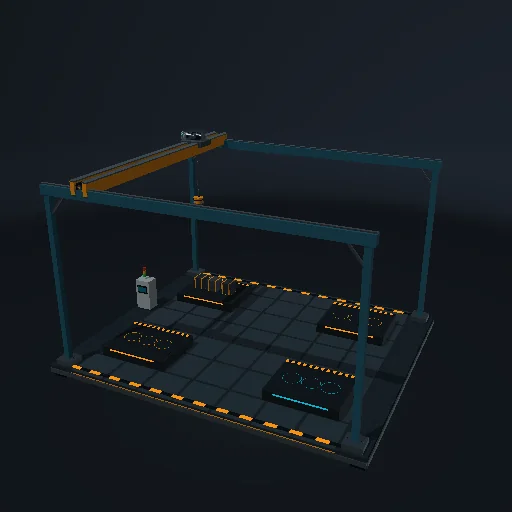
Crane and anti-sway control
Lift and transfer steel blocks with a bridge crane; compare motion with and without sway feedback.
In development
Working mechanisms, manufacturing processes and machines: from an astrolabe and cable robot to a hydrofoil and a CNC mill.
106 modules · Page 3 / 6 · 54 planned
This Suite is still in development. These are implemented experiments, not a released product.
Contact & licencesPhysics / Engineering
Lift and transfer steel blocks with a bridge crane; compare motion with and without sway feedback.
Physics / Engineering
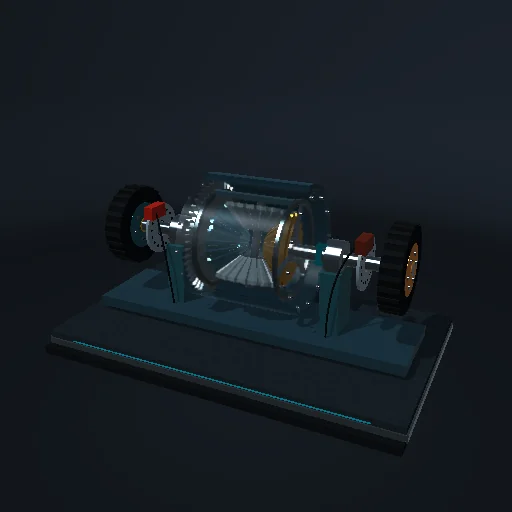
Look inside a bevel differential, brake either wheel and compare open and clutch-coupled operation.
Physics / Engineering
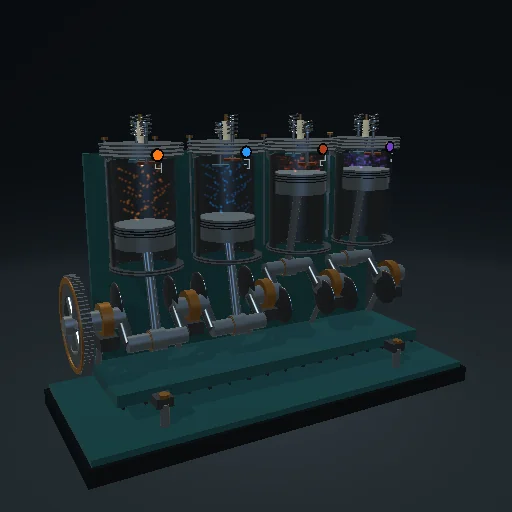
Slider-crank, an Otto cycle with a finite burn, and a shaft the gas turns.
Physics / Engineering
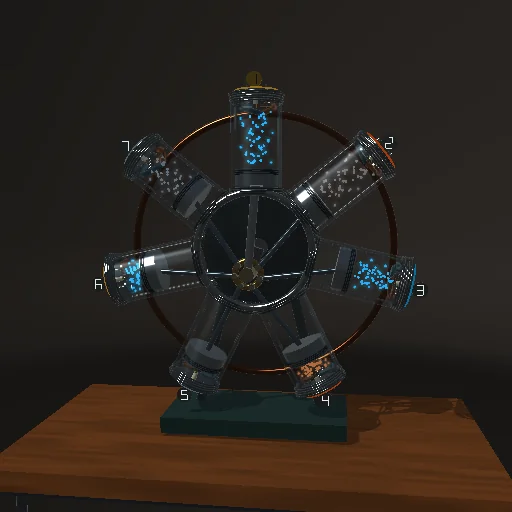
Inspect seven transparent cylinders, master and articulating rods, moving pistons, fuel injection, valves and ignition.
Physics / Engineering
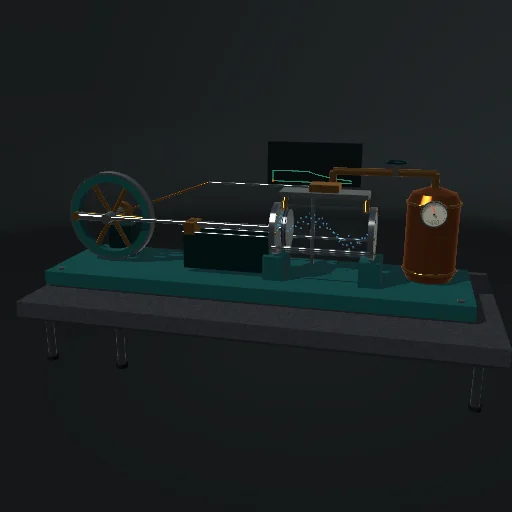
An ideal double-acting steam engine couples admission and expansion to a slider-crank and loaded flywheel. Change boiler pressure and cut-off while inspecting the indicator diagram.
Physics / Engineering
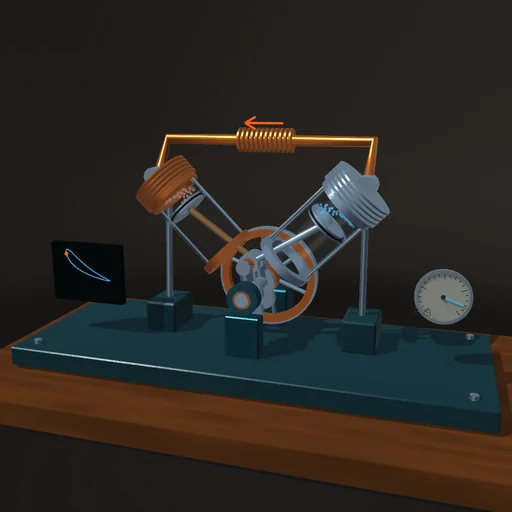
Two pistons share one crankpin in a 90° V. Inspect the rod bearings, compare reservoir temperatures and explore a separate adjustable-crank teaching mode.
Physics / Engineering
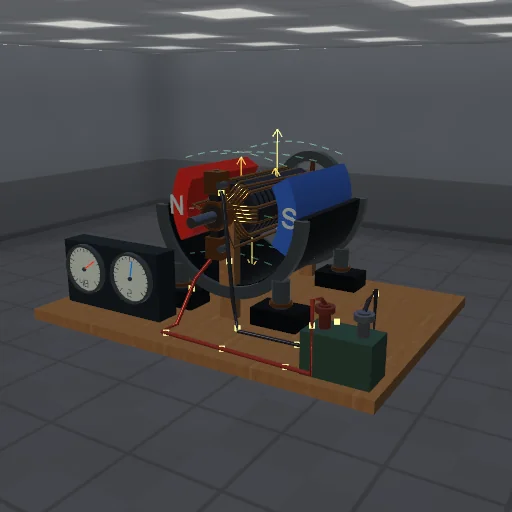
Compare a DC motor and generator with a separate three-phase FOC machine. Change the load and follow phase currents, rotor motion, speed and torque.
Physics / Engineering
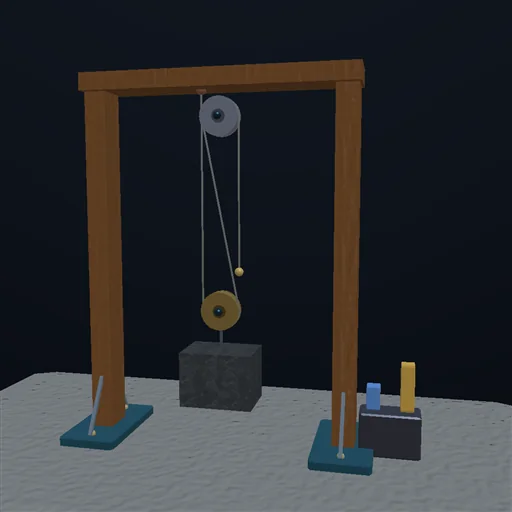
Count the rope segments and you have the mechanical advantage. The work does not change: a machine buys force with distance, never with energy.
Astronomy / Engineering
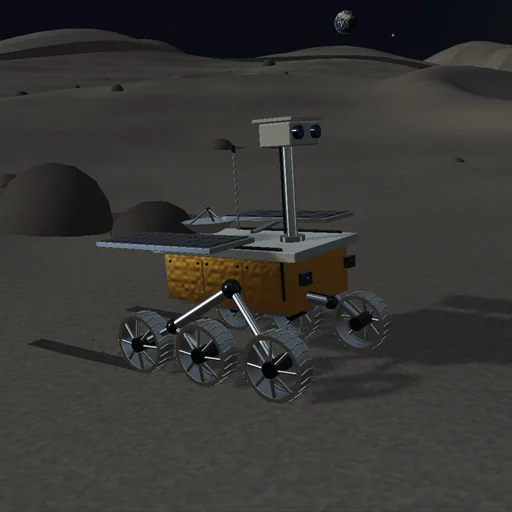
Drive a six-wheel rover across a cratered lunar test field. Compare grip, suspension loads and the automatic survey route.
Astronomy / Engineering
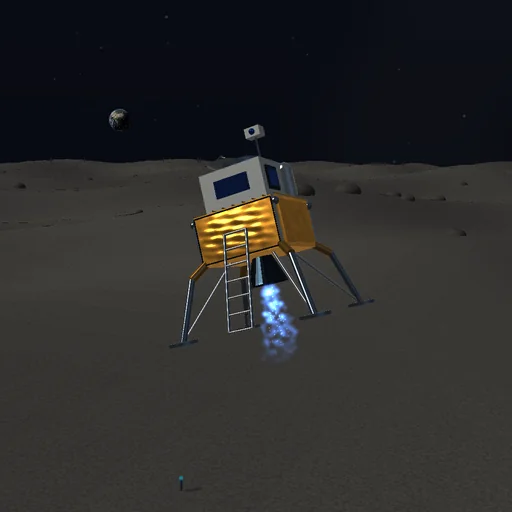
Bring the lander onto the illuminated target. Try automatic guidance, then control thrust and lateral tilt yourself while watching fuel and touchdown speed.
Physics / Astronomy / Engineering
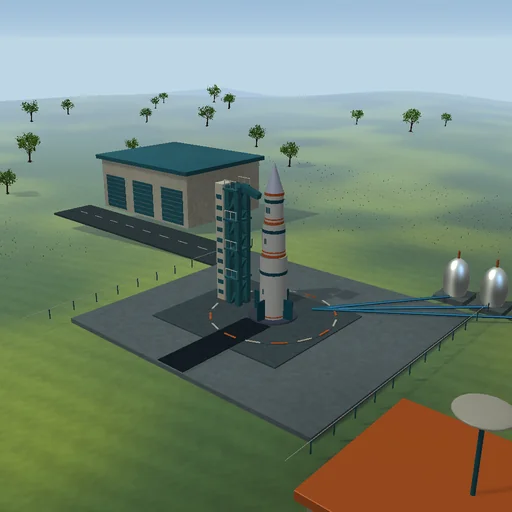
Variable mass and the Tsiolkovsky equation, staging and gravity.
Astronomy / Engineering
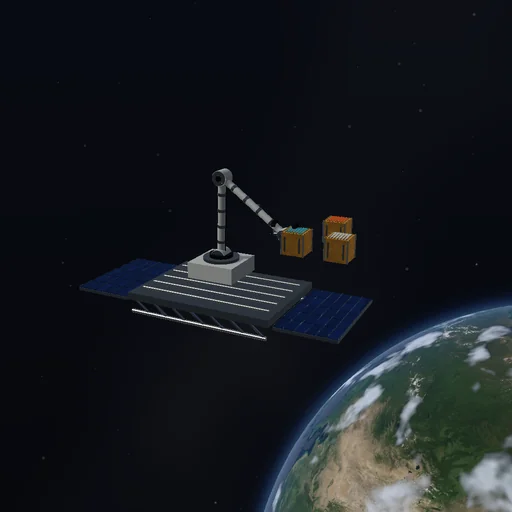
Use a station-mounted arm to capture floating cargo and move it into the service area. Compare automatic transfer with manual tool positioning.
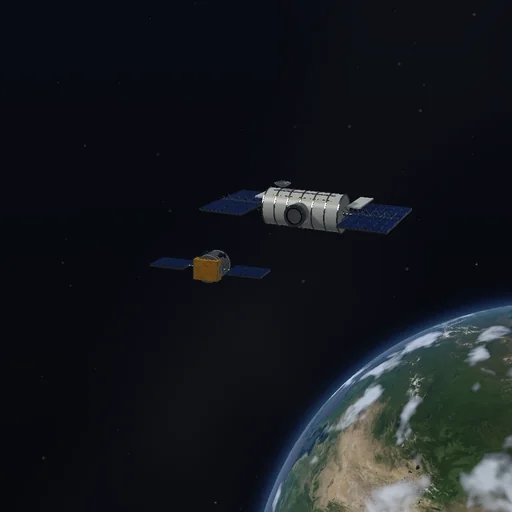
Astronomy / Engineering
Approach the station, match orientation and settle into the docking collar. Automatic guidance uses the same limited thrusters as your manual commands.
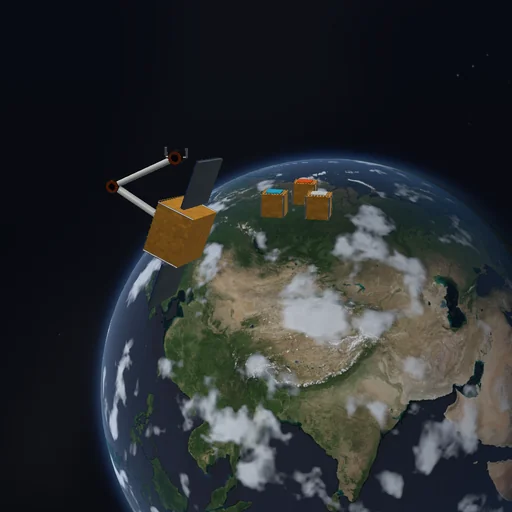
Astronomy / Engineering
Catch a drifting payload with a robot that has no fixed support. Moving the captured load pushes and turns the floating base through the same contact solver.
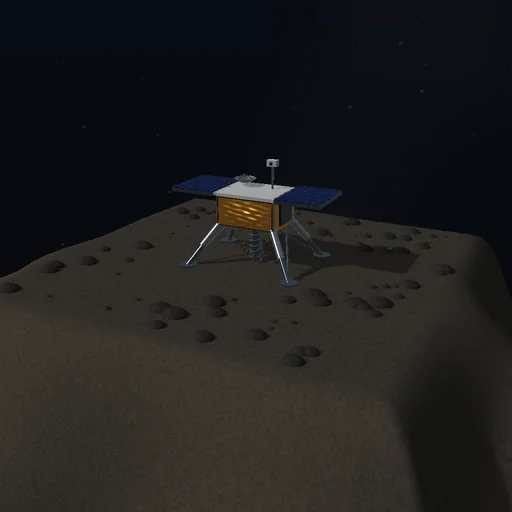
Astronomy / Engineering
Operate a drill where gravity is extremely weak. Anchor the machine before drilling, then release it and see the reaction push the rig away.
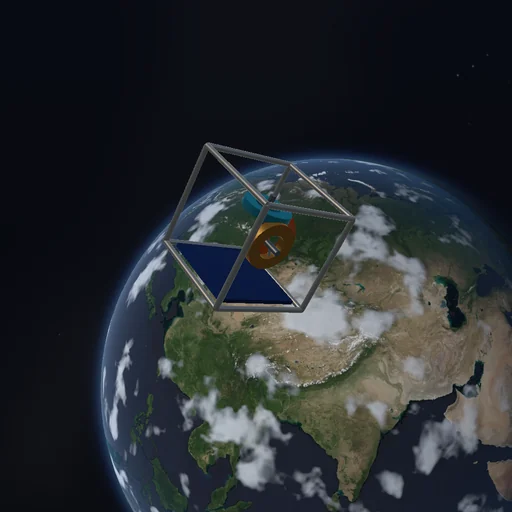
Astronomy / Engineering
Turn the satellite using three internal flywheels. Watch angular momentum move between wheels and body, then unload saturated wheels with external thrusters.
Engineering
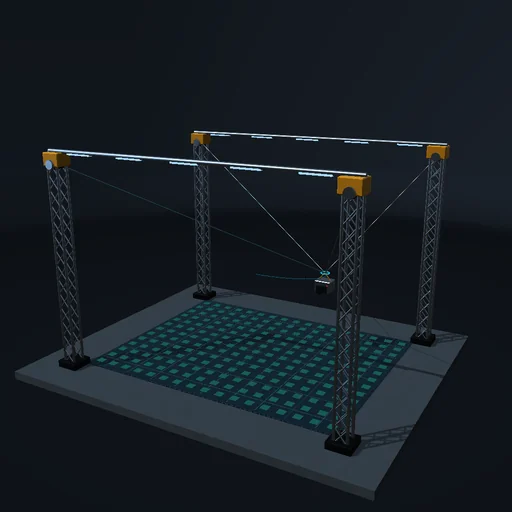
Four finite-power winches carry a camera through an arena. Explore tension, passive sway, slack cables and the limits of the reachable workspace.
Engineering
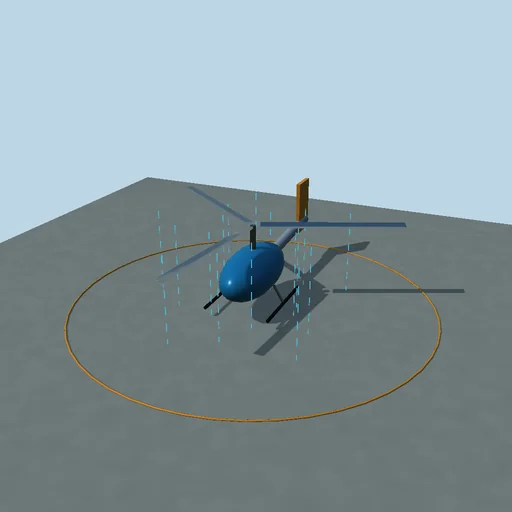
Change collective pitch and rotor speed; compare blade-element thrust, induced flow and the power needed to hover.
Engineering
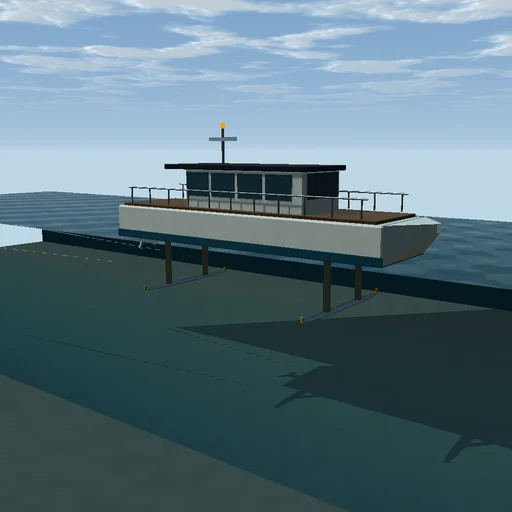
Accelerate a boat onto submerged wings. Balance lift, buoyancy, drag and pitch, switch off the height controller and watch the return to displacement sailing.
Engineering
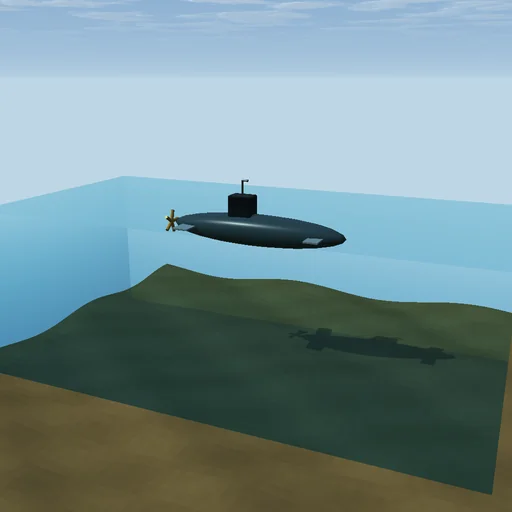
Flood or empty the ballast tanks and balance buoyancy, diving planes and propulsion in a water-column cutaway.
Some modules belong to more than one Suite. Shared experiments have one description here.