Engineering
Four-bar linkage
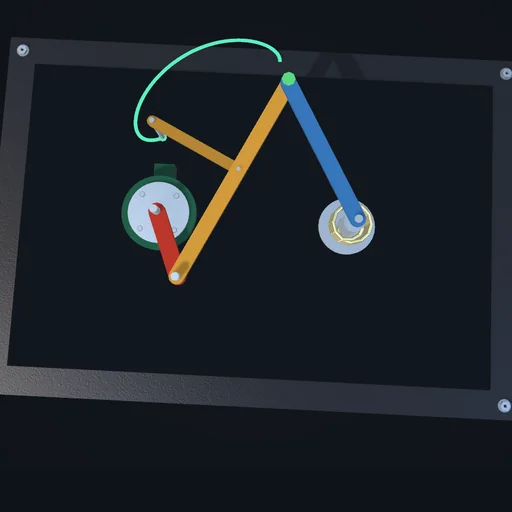
Switch between a crank-rocker, a drag link and a triple rocker and watch the transmission angle: near a dead point the drive labours, and the triple rocker stalls and turns back. The coupler draws its curve on the plate.
In development
Working mechanisms, manufacturing processes and machines: from an astrolabe and cable robot to a hydrofoil and a CNC mill.
106 modules · Page 2 / 6 · 54 planned
This Suite is still in development. These are implemented experiments, not a released product.
Contact & licencesEngineering
Switch between a crank-rocker, a drag link and a triple rocker and watch the transmission angle: near a dead point the drive labours, and the triple rocker stalls and turns back. The coupler draws its curve on the plate.
Engineering
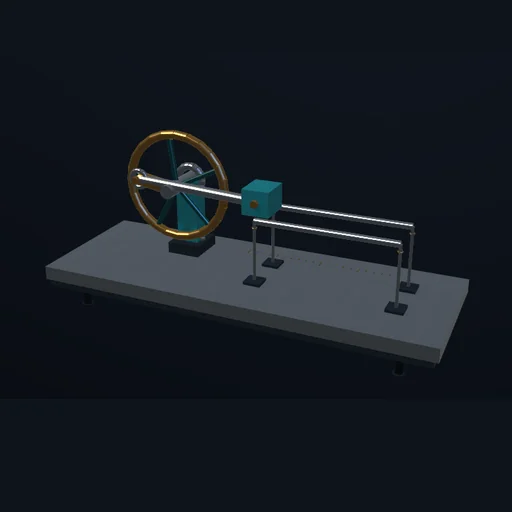
The crank drives a guided piston through a connecting rod. Compare stroke, speed and load at finite motor torque.
Engineering
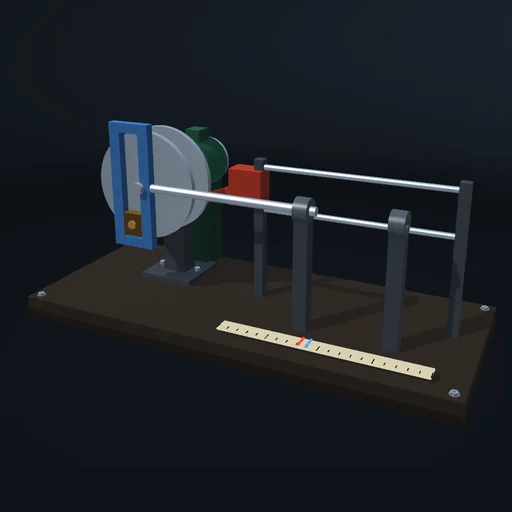
Run a Scotch yoke and a slider-crank from the same crank: equal strokes, but only the yoke moves as a pure cosine. Shorten the connecting rod and watch the difference grow; load the outputs and compare the crank torque.
Engineering
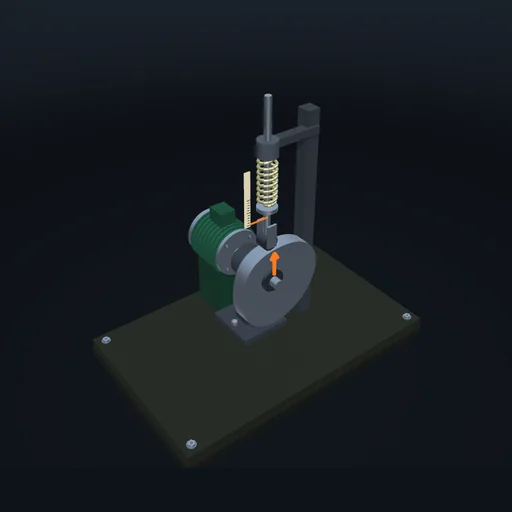
Compare three smooth lift laws and raise the speed until the roller leaves the cam; then stiffen the spring until contact returns. The contact can only push, so a lift-off is computed, not drawn.
Engineering
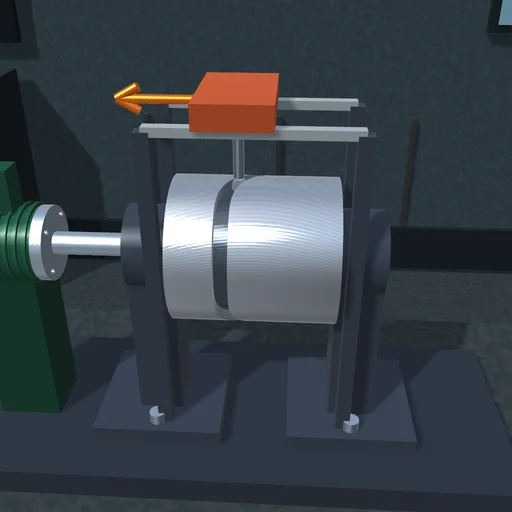
The groove round the drum moves the carriage out, holds it, brings it back and holds it again. Shorten the rise and watch the groove lean steeper and the drum torque climb; give the roller more friction and see the load drive the drum back on the return only while the groove is steep.
Engineering
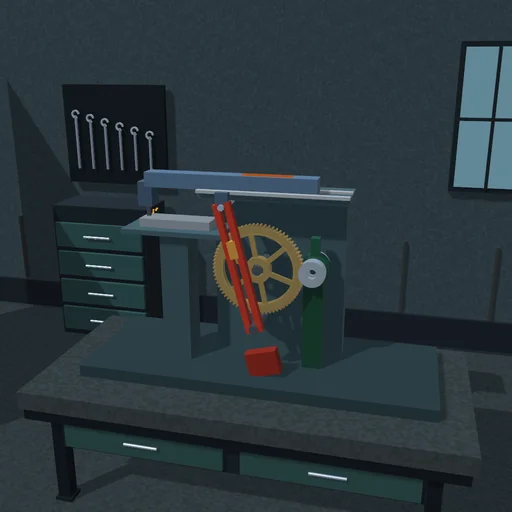
The crank turns steadily, yet the ram cuts slowly and comes back fast. Change the crank radius and watch the time ratio of the strokes; load the cut and see the motor torque rise on the slow stroke while the wheel carries the ram through the quick return.
Engineering
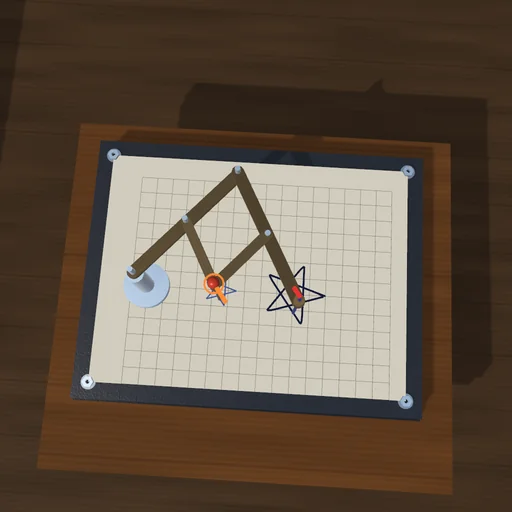
Lead the stylus round a figure and watch the pen draw it two or three times larger. Compare the forces: the hand pushes k times as hard as the pen drags. Switch the hand off and push the stylus with a steady force: below k times the drag nothing moves.
Engineering
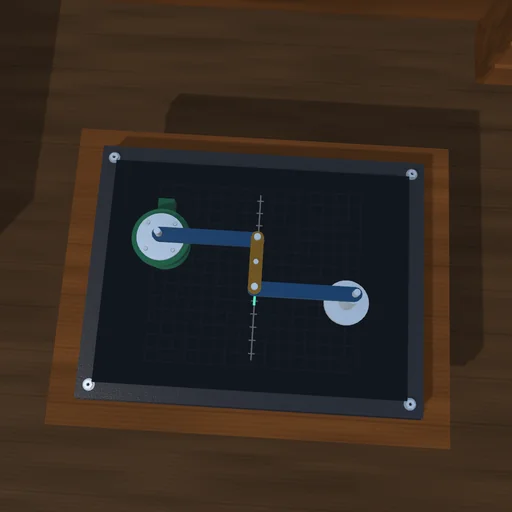
Swing the left lever and watch the pen in the middle of the coupler: within ±15° it stays within a fraction of a millimetre of the ruled line, then curls away. Move a support or change the bars and compare the path; push across the line and see the motor feel the push only away from the centre.
Engineering
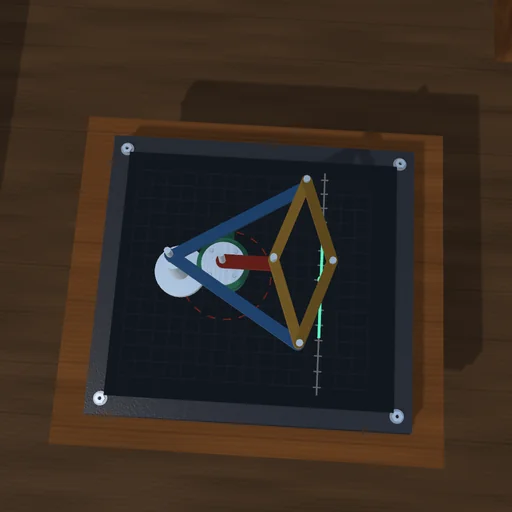
Swing the crank and watch the pen at the far corner of the rhombus run along the ruled line, exactly. Push the pen across the line: the crank feels nothing. Then move the crank’s pivot a centimetre and see the line turn into a large circle.
Engineering
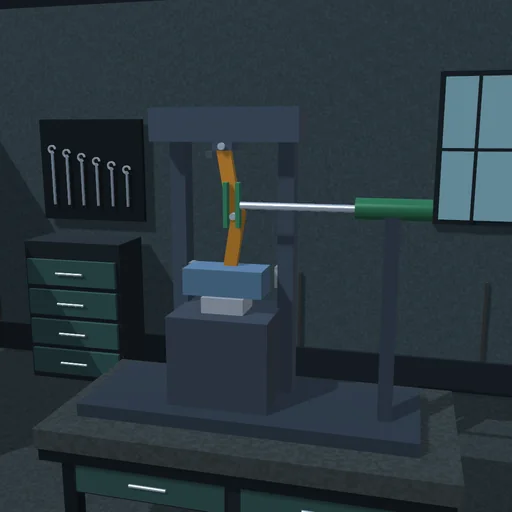
Push the knee with a few hundred newtons and watch the press force grow as the links straighten. On steel the knee stops short of the centre; push harder, or press wood, and it goes over the centre and locks - switch the actuator off and the press still holds.
Engineering
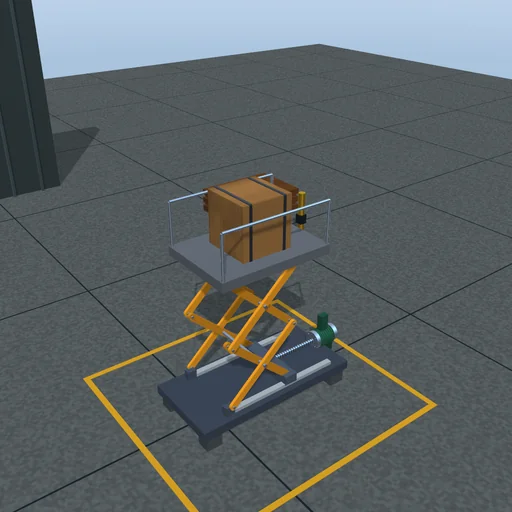
Raise the deck with one, two or three stages and watch the screw’s pull: it is greatest at the bottom and falls as the arms rise. Move the load along the deck: the pull stays the same, only the pin and the roller under the deck share the load differently.

Engineering
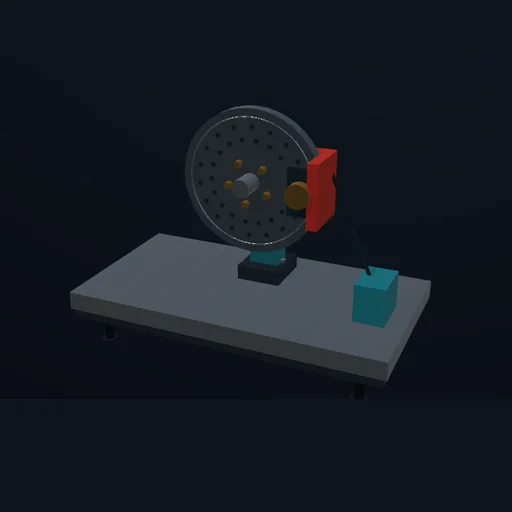
Engage the clutch abruptly and gently, then with double the flywheel inertia: against a motor that holds its speed, the slip heat equals the energy the flywheel gains, whatever the ramp.
Engineering
Spin the disc, disconnect the motor and brake. Compare friction, stopping and heat; keep the motor on to study sustained heating.
Engineering
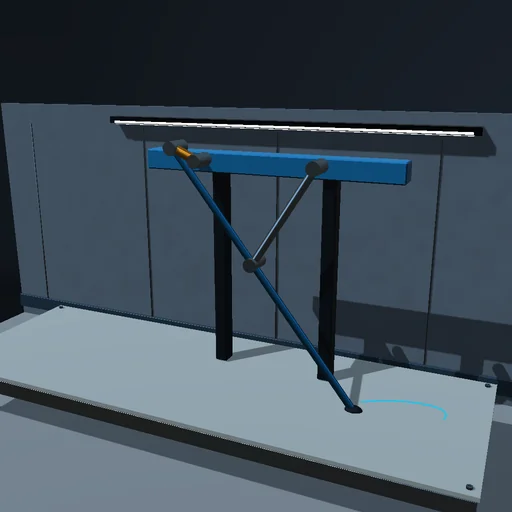
A closed four-bar leg turns rotation into a curved foot path. Compare the linkage with its measured trajectory.
Engineering
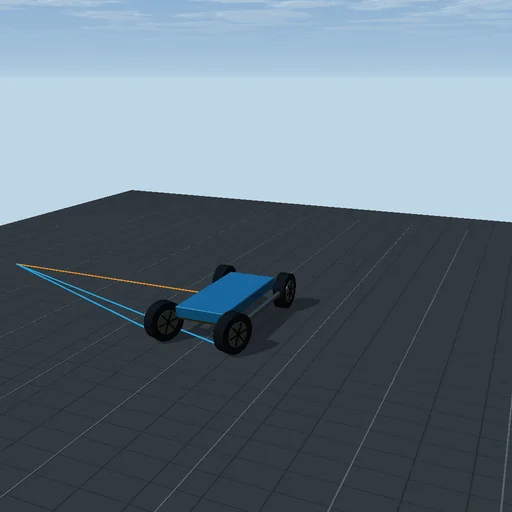
Turn the front wheels and compare the inner and outer angles required for rolling around a shared centre.

Engineering
Close the jaws, lift a payload, and discover when limited normal force and friction let it slip.

Physics / Engineering
Explore four-legged locomotion, terrain, grip and balance with an articulated 3D robot.
Physics / Engineering
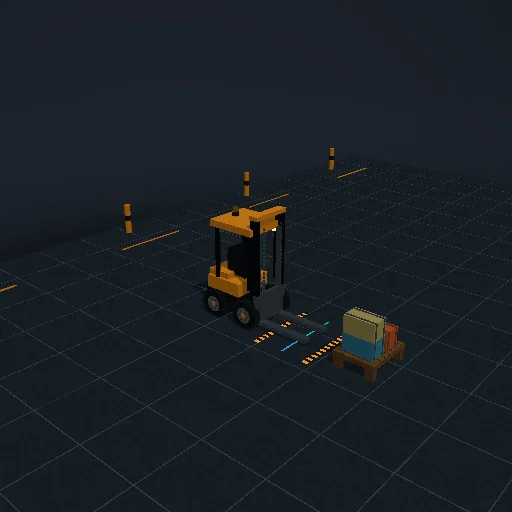
Drive a forklift and transport pallets with loose crates that interact through contact and friction.
Physics / Engineering
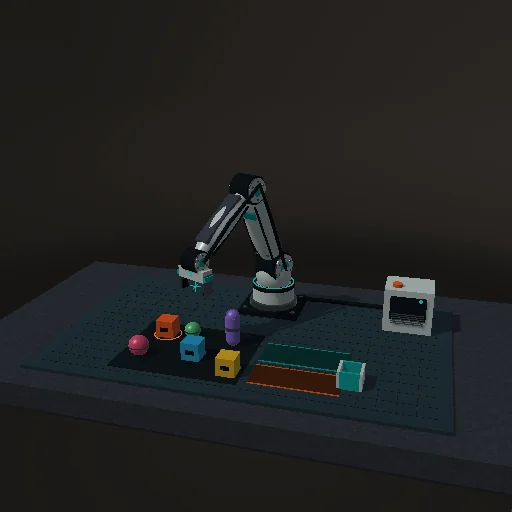
Control a six-axis robot arm, grasp physical objects, sort a mixed batch or build a tower. Explore inverse kinematics, joint limits and payload with the suite’s 3D contact solver.
Physics / Engineering
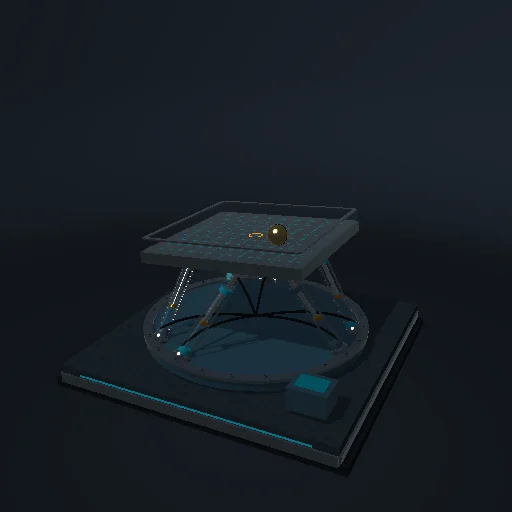
Control a six-actuator parallel robot and balance a freely rolling ball on its moving platform.
Some modules belong to more than one Suite. Shared experiments have one description here.